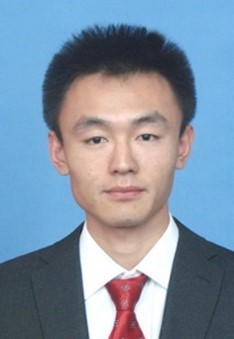
许男
1988 年生,工学博士。现任吉林大学唐敖庆领军教授、汽车研究院副院长、中国汽车工程学会汽车动力学分会副秘书长。曾任加拿大滑铁卢大学访问学者,入选中国科协第四届青年人才托举工程。任《SAE International Journal of Vehicle Dynamics, Stability, and NVH》副主编,《International Journal of Vehicle Design》客座主编。
研究方向为智能汽车运动控制;智能汽车状态感知、决策与规划;节能与新能源汽车;车辆动力学与控制;智能轮胎。主持国家自然科学基金项目3项、中国博士后面上资助及特别资助项目;国家自然科学基金重大项目子课题2项;作为项目骨干参加中国汽车产业创新发展联合基金项目2项,国家重点研发计划3项。在Materials Today(IF26.943)、IEEE T-SMC(IF 13.451)、Applied Energy(IF 8.426)、MSSP(IF 6.471)、IEEE T-ITS(IF 6.319)、VSD(IF 2.581)等“车辆动力学与控制”权威期刊发表论文70余篇,获省部级一等奖3项。
主要研究方向:
智能汽车运动控制;智能汽车状态感知、决策与规划;节能与新能源汽车;车辆动力学与控制;智能轮胎。
主要科研项目:
1.国家自然科学基金面上项目,52372385,融合胎内传感的智能底盘关键状态估计与轨迹跟踪协调控制,2024.01-2027.12,直接经费49万元,运行,项目负责人
2.国家自然科学基金重大项目,52394263,模块化分布式电驱动重载车辆设计理论与系统控制技术,2024.01-2028.12,直接经费1300万元,运行,子课题负责人
3.国家重点研发计划,2023YFB2504404,高级别自动驾驶车辆安全决策规划技术,2023.12-2026.11,直接经费514万元,运行,子课题负责人
4.国家重点研发计划,2022YFB3206602,智能轮胎多参量传感阵列协同优化及动力学特性实时感知,2022.12-2025.11,直接经费500万元,运行,子课题负责人
5.国家自然科学基金重大项目,61790560,极限工况下汽车主动安全协同控制及应用验证,2018.01-2022.12,直接经费1739.2万元,结题,子课题负责人
6.国家自然科学基金面上项目,51875236,智能轮胎胎/路参数估计及四轮驱动电动汽车轮胎力最优分配控制,2019/01-2022/12,直接经费60万,结题,项目负责人
7.国家自然科学基金联合基金项目,U1664257,四轮驱动电动汽车底盘系统动态协调控制机制与能量优化管理,2017/01-2020/12,234万元,结题,项目骨干。
8.国家自然科学基金联合基金项目,U1564213,智能汽车行驶动力学建模与多目标优化控制技术,2016/01-2019/12,270.98万元,结题,项目骨干。
9.国家自然科学基金青年基金项目,51405185,胎面橡胶摩擦机理及复杂工况下轮胎力学特性研究,2015/01-2017/12,25万元,结题,项目负责人。
10.中国科协项目,3D5203558462,2018-2020 年度青年人才托举工程项目,2018/05-2021/05,45万元,结题,项目负责人。
代表性学术成果:
[1] Nan Xu, Hassan Askari, Amir Khajepour. Intelligent tire system[M]. Springer, 2022.
[2] Xu N, Yin Z, Zhang Y, et al. Extended Stability Envelopes and Effectiveness Quantification for Integrated Chassis Control With Multiple Actuator Configurations in the Energy Phase Plane[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2025, 55(10): 7472-7486.
[3] Xu N, Wang Z, Askari H, et al. Intelligent mobility: Unveiling triboelectric nanogenerator-powered intelligent tire realization[J]. Applied Materials Today, 2025, 42: 102506.
[4] Xu N, Hu M, Jin L, et al. Combined-slip trajectory tracking and yaw stability control for 4WID autonomous vehicles based on effective cornering stiffness[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(12): 20683-20697.
[5] Xu N, Zhou J, Barbosa B H G, et al. A Soft Sensor for Estimating Tire Cornering Properties for Intelligent Tires[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2023, 53(10): 6056-6066.
[6] Xu N, Hashemi E, Tang Z, et al. Data-Driven Tire Capacity Estimation With Experimental Verification[J]. IEEE Transactions on Intelligent Transportation Systems, 2022.
[7] Askari H, Xu N, Barbosa B H G, et al. Intelligent systems using triboelectric, piezoelectric, and pyroelectric nanogenerators[J]. Materials Today, 2022, 52: 188-206.
[8] Xu N, Askari H, Huang Y, et al. Tire Force Estimation in Intelligent Tires Using Machine Learning[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(4): 3565-3574.
[9] Xu N, Huang Y, Askari H, et al. Tire slip angle estimation based on the intelligent tire technology[J]. IEEE Transactions on Vehicular Technology, 2021, 70(3): 2239-2249.
[10] Li X, Xu N, Guo K, et al. An adaptive SMC controller for EVs with four IWMs handling and stability enhancement based on a stability index[J]. Vehicle System Dynamics, 2021, 59(10): 1509-1532.
联系方式:
电话:15044005805;
邮箱:xunan@jlu.edu.cn;
地址:吉林省长春市人民大街5988号吉林大学汽车底盘集成与仿生全国重点实验室,130022
下一篇:高镇海